- The November 13 analysis discusses products introduced on November 9.
- Predicting contact from images remains exploratory and does not replace tactile measurement.
Capturing complementary signals
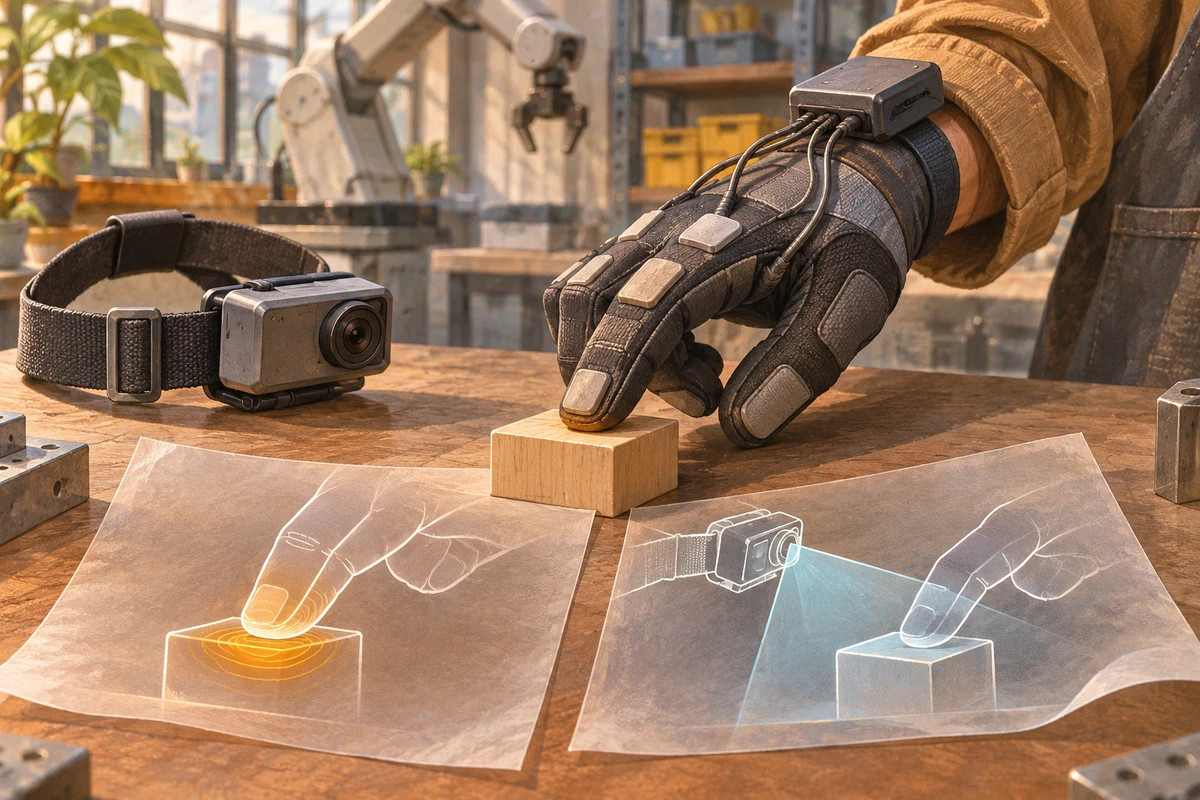
A November 13 QbitAI analysis examines how GenRobot combines first-person video, wrist cameras and tactile gloves to collect human demonstrations for robot training. It discusses DAS Ego 2.0 and DAS Dex 2.0, introduced at CoRL on November 9, rather than a new launch today.
The report explains that cameras can capture task context and visible movement, while gloves add joint-motion and physical-contact measurements. It describes a proposed combination of synchronized camera and glove recordings that could provide paired supervision for models learning to infer contact from images.
An exploratory transfer route
The intended approach would transfer information from measured touch to a lighter camera-based setup through paired supervision or knowledge distillation. QbitAI stresses that this remains an exploratory technical route: hidden contact and object weight may not be recoverable from pictures, and predicted contact cannot directly substitute for measurement.
Human demonstrations also need adaptation to different robot bodies and movement constraints. QbitAI reports that GenRobot’s data products have been validated in teams' models including Vidu AI. This is a reported training-workflow connection, not an independently verified deployment or measured performance benefit.
Sources & context
Go to the original material. Company claims remain attributed to their sources.
01