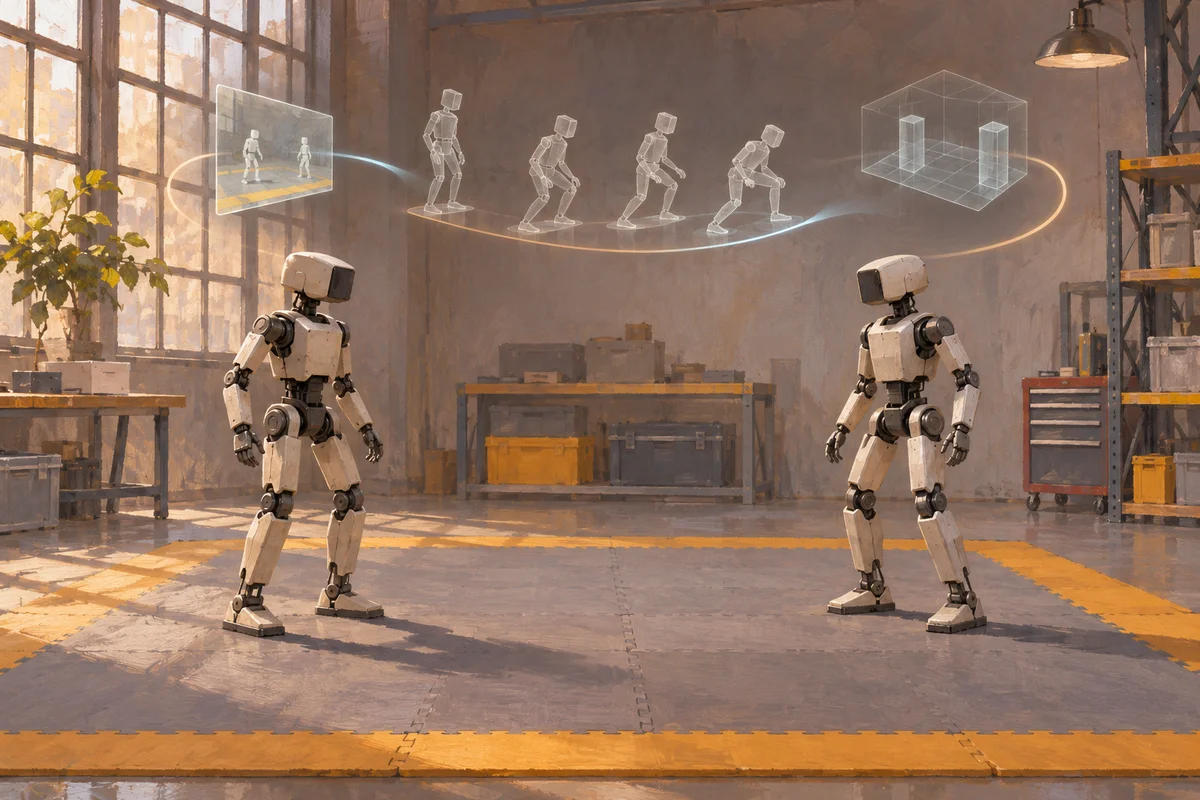
- Wang describes visual input feeding an end-to-end world model for robot-sparring decisions.
- The reported current action set and future training ambitions are distinct and independently untested here.
A demonstration described at Hongqiao
Unitree founder Wang Xingxing described an autonomous robot-sparring demonstration at a Hongqiao forum on November 5, according to reporting by The Paper's Qin Sheng. Wang said the robots collect images in real time and use an end-to-end world model to infer decisions directly.
He said the work had been completed over the preceding month or two and currently supports roughly a dozen to twenty actions. His suggestion that training could enable hundreds or thousands of combined actions was prospective, rather than a description of the present system.
Feedback remains a development goal
Wang also discussed an automated improvement loop involving data collection, labeling, training, evaluation and model iteration. He said progress toward such automation in robotics, including at Unitree, had been relatively slow compared with large-model companies.
The account reports a specific demonstration and the founder's development plans, not an independent benchmark of robustness or general-purpose competence. This brief has not tested the robots. Performance in a sparring demonstration does not establish safety or reliable task completion in unrelated human environments.
Sources & context
Go to the original material. Company claims remain attributed to their sources.
01