- The reported validation concerns a robot-learning approach, rather than proof of general commercial autonomy.
Learning from other robots
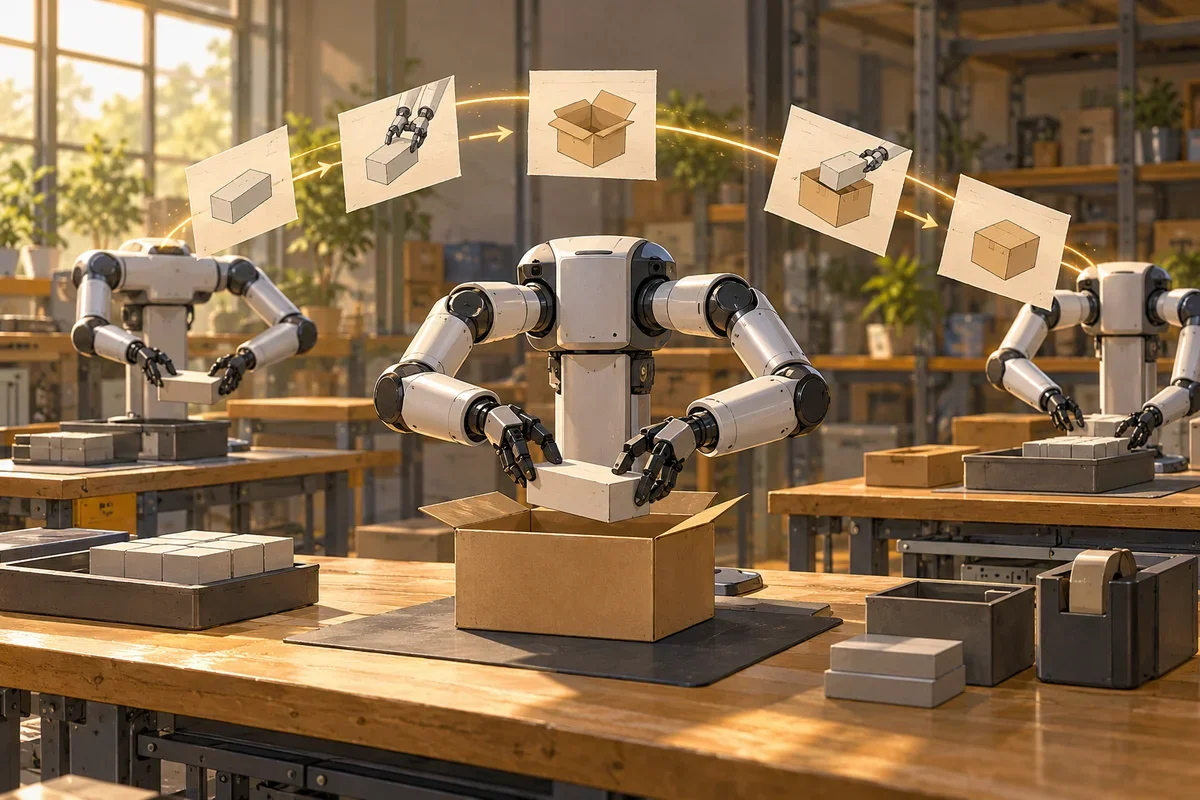
Tsinghua University, Infinigence and AgiBot have proposed Collective Experience Learning, or CEL, and validated it in a cluster of 96 real robots, according to an October 30 report by Chinese financial news service CLS. The wire described the research as recent without giving an exact date for the experiment.
The approach lets robots draw on successful experience accumulated by other machines, rather than relying solely on demonstrations from people. Shared experience is intended to help the group improve through continued practice.
A shared experience pool
A separate account supplied by Infinigence and republished with permission by QbitAI describes a training system built on the RLinf reinforcement-learning framework. It says the system collects robot experience asynchronously and uses past successes to guide improvements after failures.
The work addresses a practical scaling question: how to improve deployed robots when skilled human operators cannot provide unlimited demonstrations and corrections. The reports describe research validation and the proposed learning mechanism; they do not establish that the approach generalizes to every task or has already achieved broad commercial deployment.
Sources & context
Go to the original material. Company claims remain attributed to their sources.
01